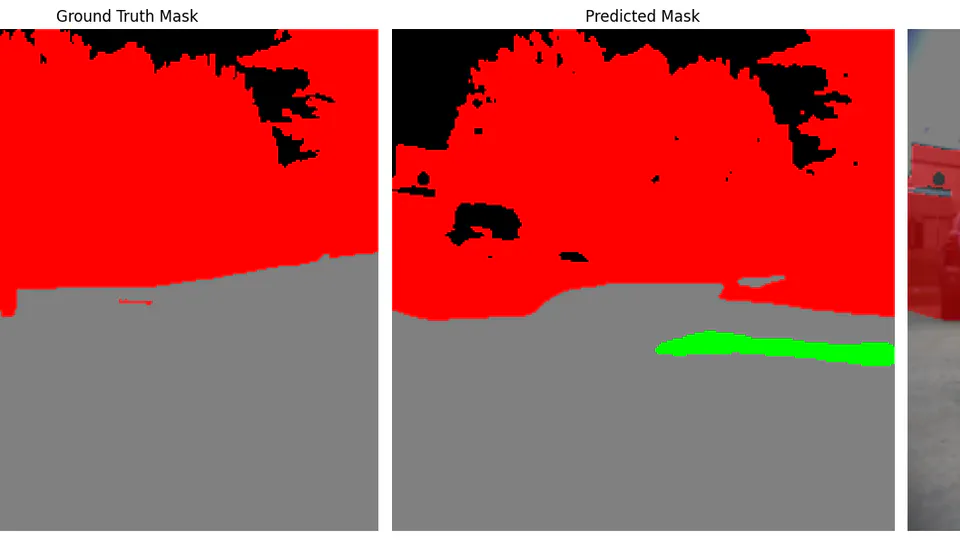
Semantic segmentation system tailored for off-road environments to facilitate autonomous navigation of vehicles.
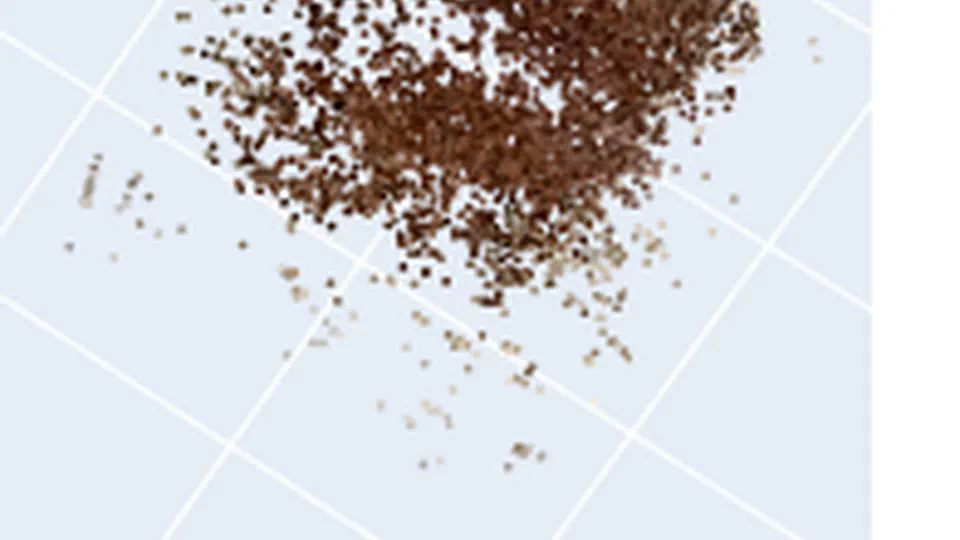
3D Reconstruction
Easily learn JavaScript in 10 minutes!
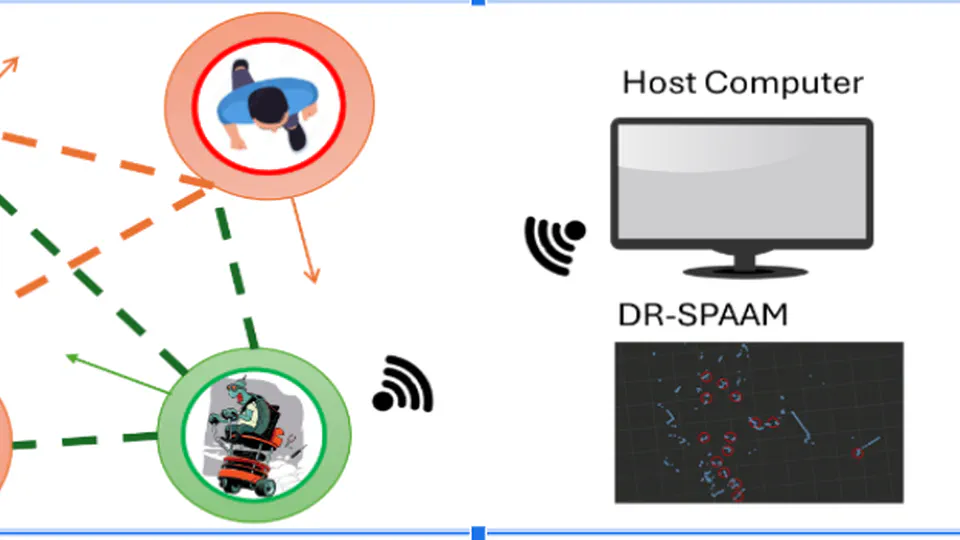
Local navigation for autonomous mobile robots in crowded environments, leveraging deep reinforcement learning (DRL) techniques
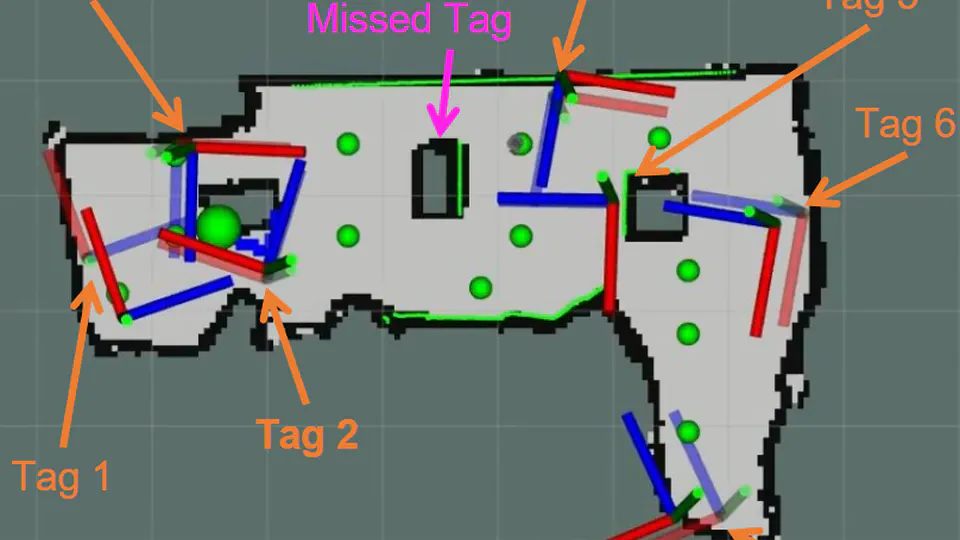
Developed an autonomous reconnaissance system on Turtlebot3 robot using SLAM, AprilTag detection, and frontier exploration to map environments and locate simulated victims in disaster scenarios.
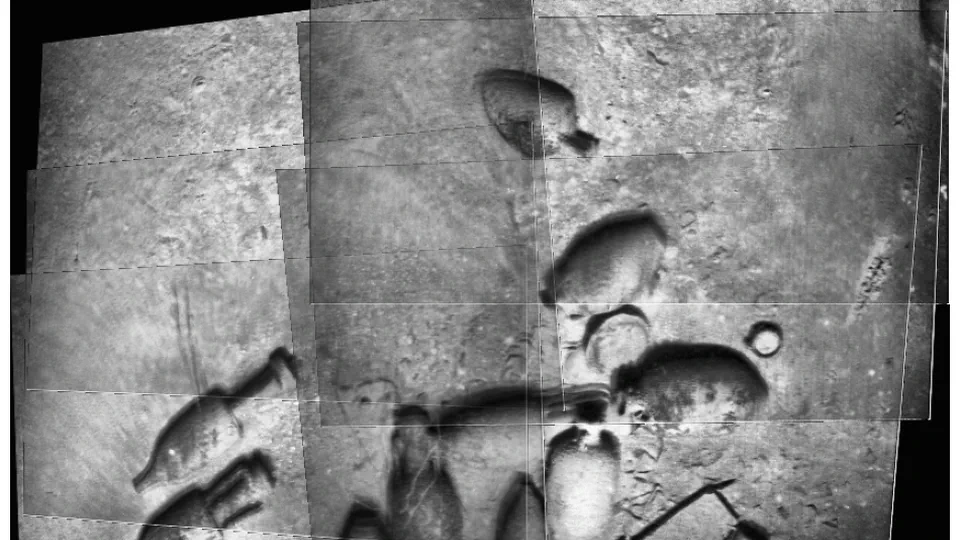
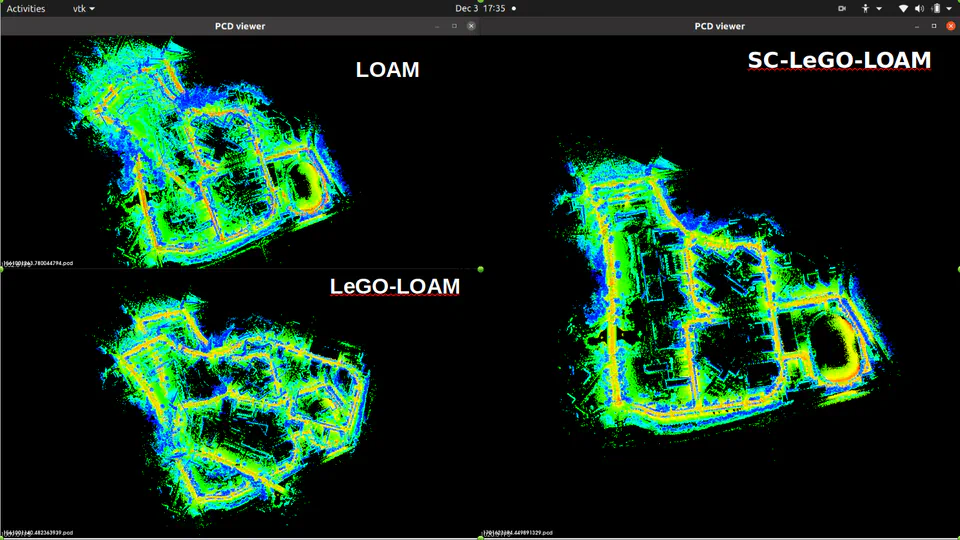
Evaluation of comprehensive SLAM systems, namely Lego- LOAM and SC-LEGO-LOAM
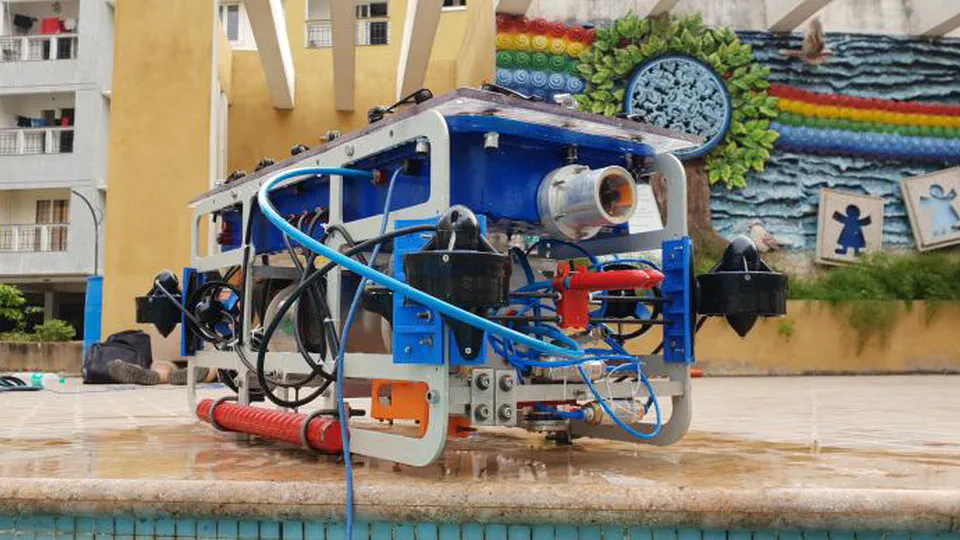
SRMAUV- Autonomous Underwater Vehicle