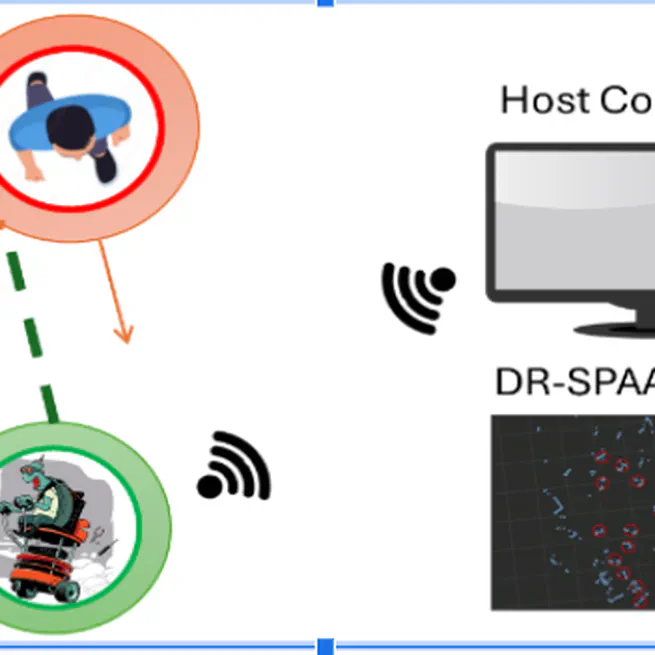
Local navigation for autonomous mobile robots in crowded environments, leveraging deep reinforcement learning (DRL) techniques
May 1, 2024